Visual Imitation Made Easy
UC Berkeley × Meta (FAIR) × CMU × NYU
In Short
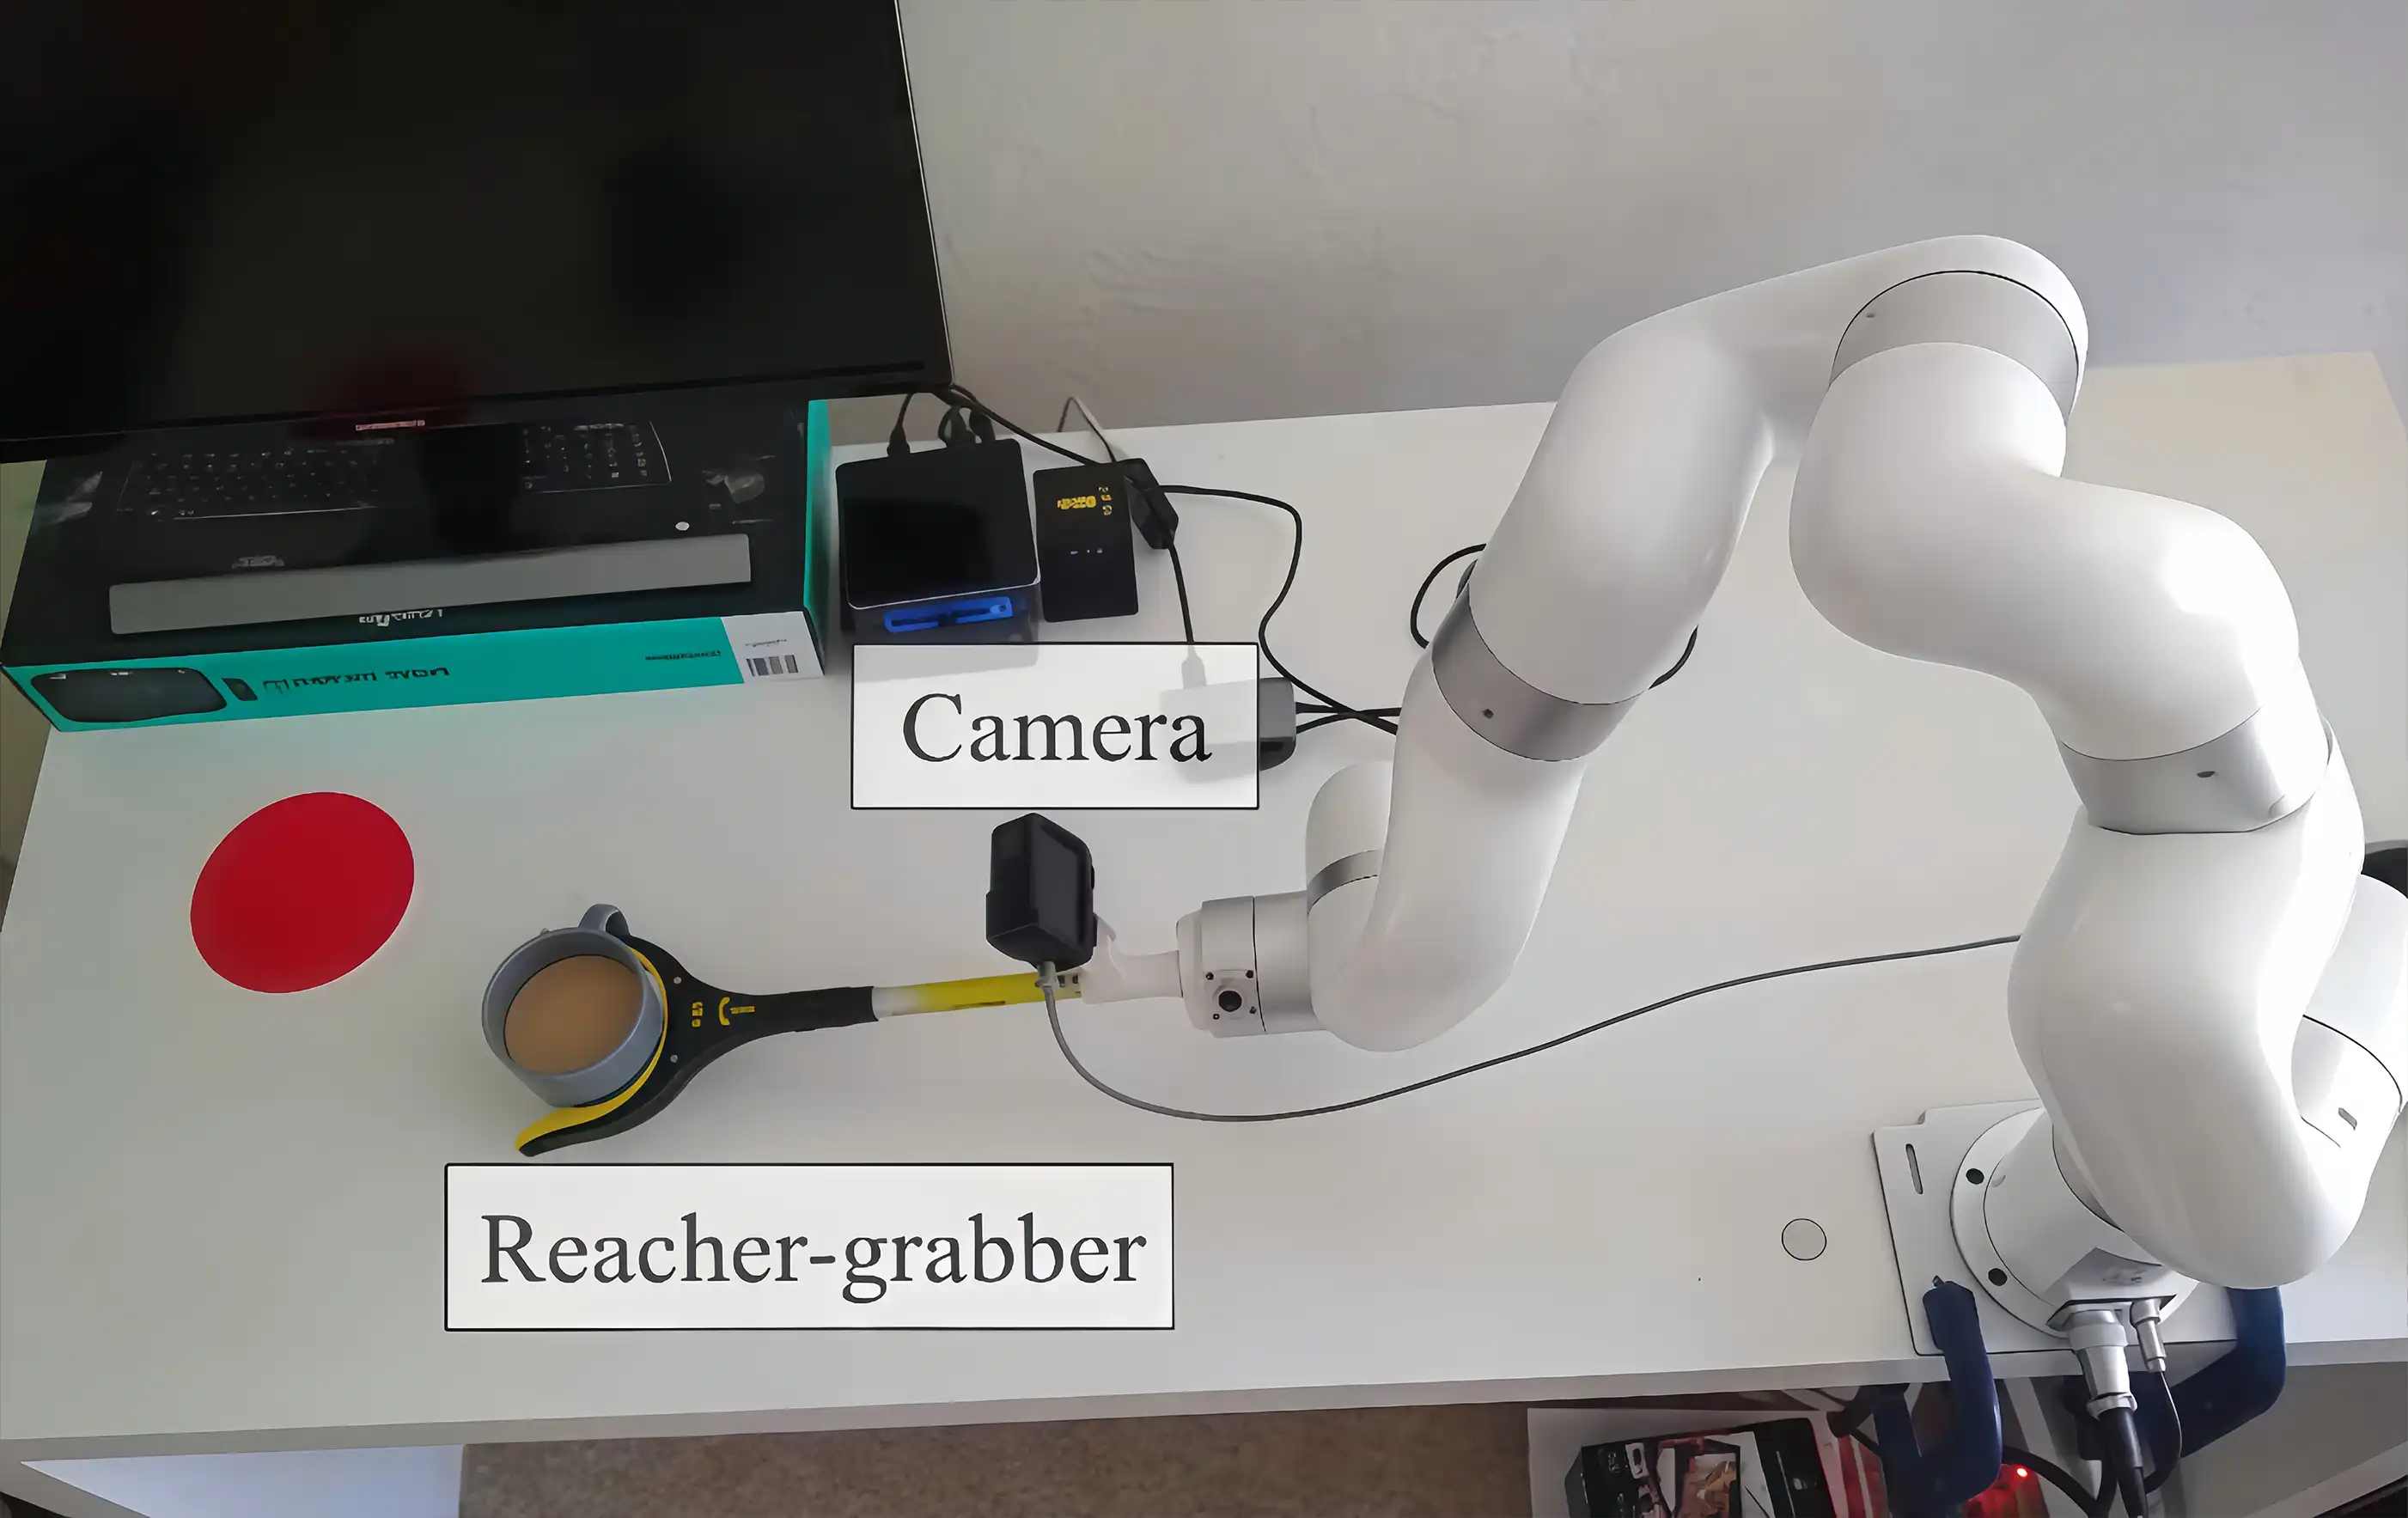
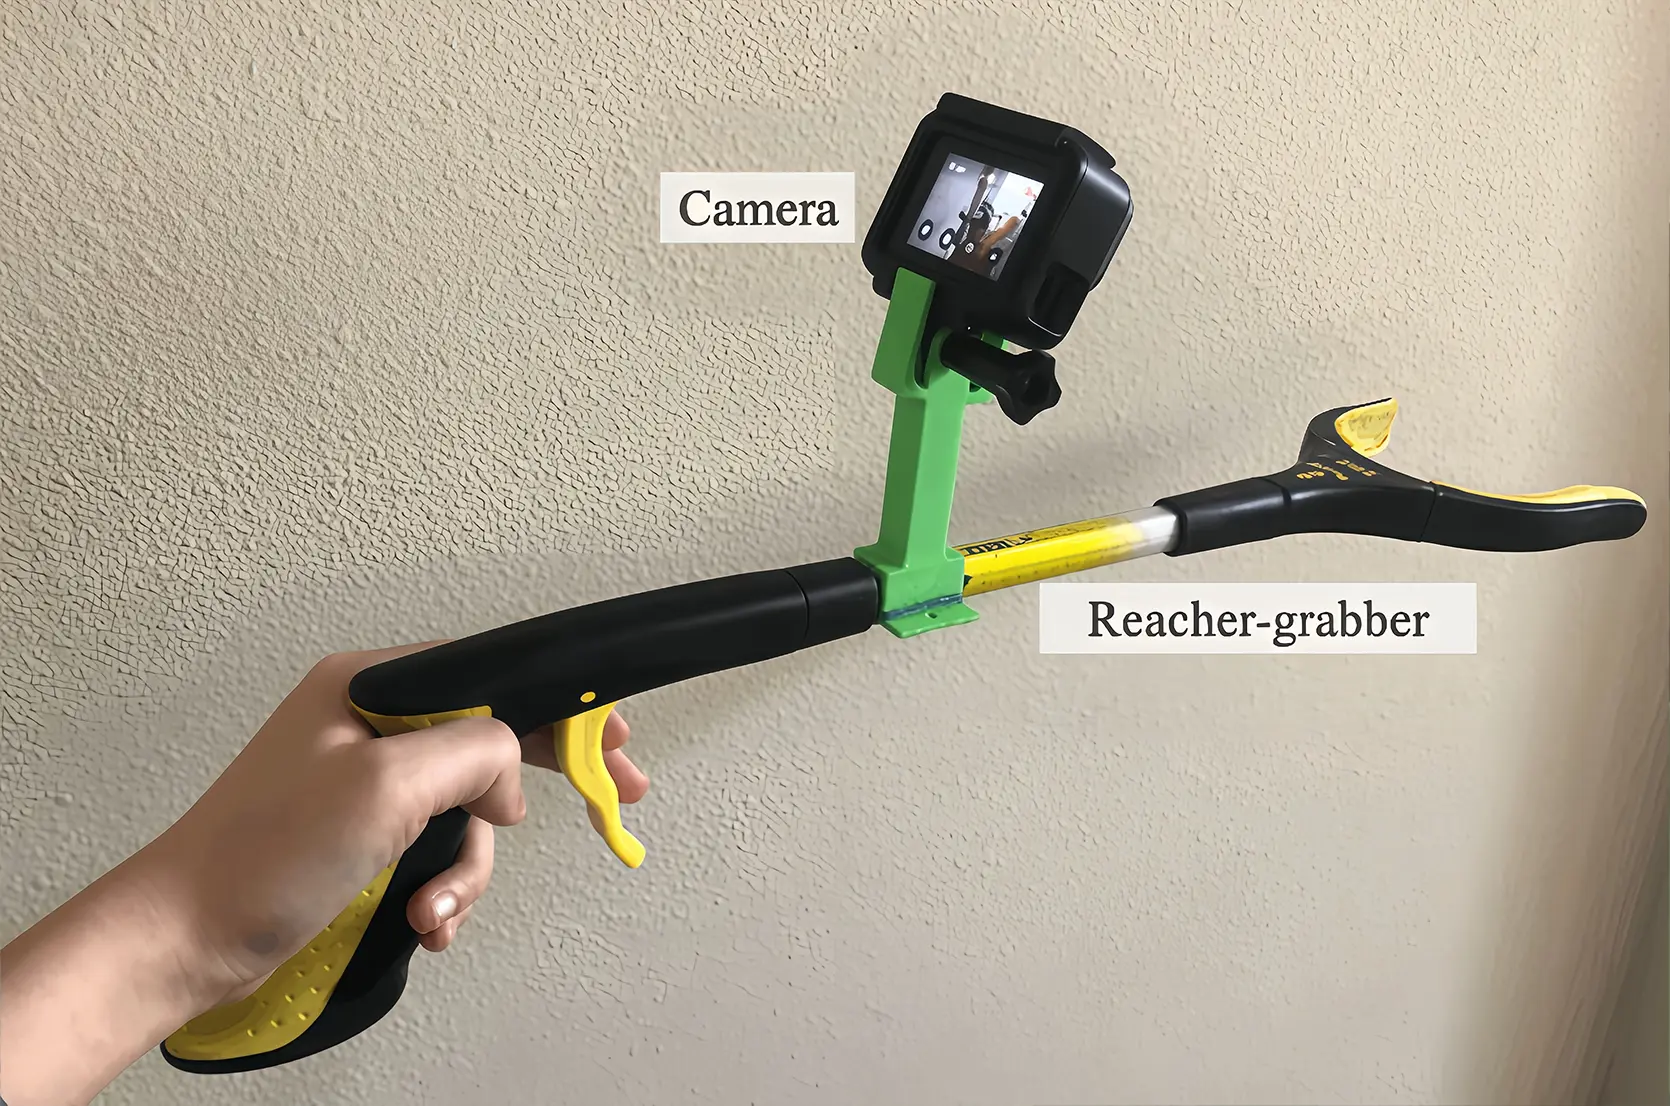
A research team from UC Berkeley, Meta (FAIR), CMU, and NYU developed a scalable, low-cost solution for collecting manipulation demonstrations “in the wild” using a handheld reacher-grabber and a GoPro camera. The same tool was then mounted on a UFACTORY xArm 7 as the robot end-effector, enabling policies learned entirely from human demonstrations to transfer directly to the robot. The system achieved approximately 87% success on pushing tasks and 62% on stacking tasks with unseen objects.
Customer Profile

Organization:
UC Berkeley, Meta FAIR, CMU, NYU

Region:
United States

Industry:
Research & Education

Robot used:
UFACTORY xArm 7

Application:
Imitation learning Learning
Key Benefits
Served as a reliable, programmable robotic platform for executing learned manipulation policies on previously unseen objects.
Supported a custom reacher-grabber end-effector actuated by a Dynamixel motor, maintaining tool consistency between human demonstration and robot execution.
Task solved
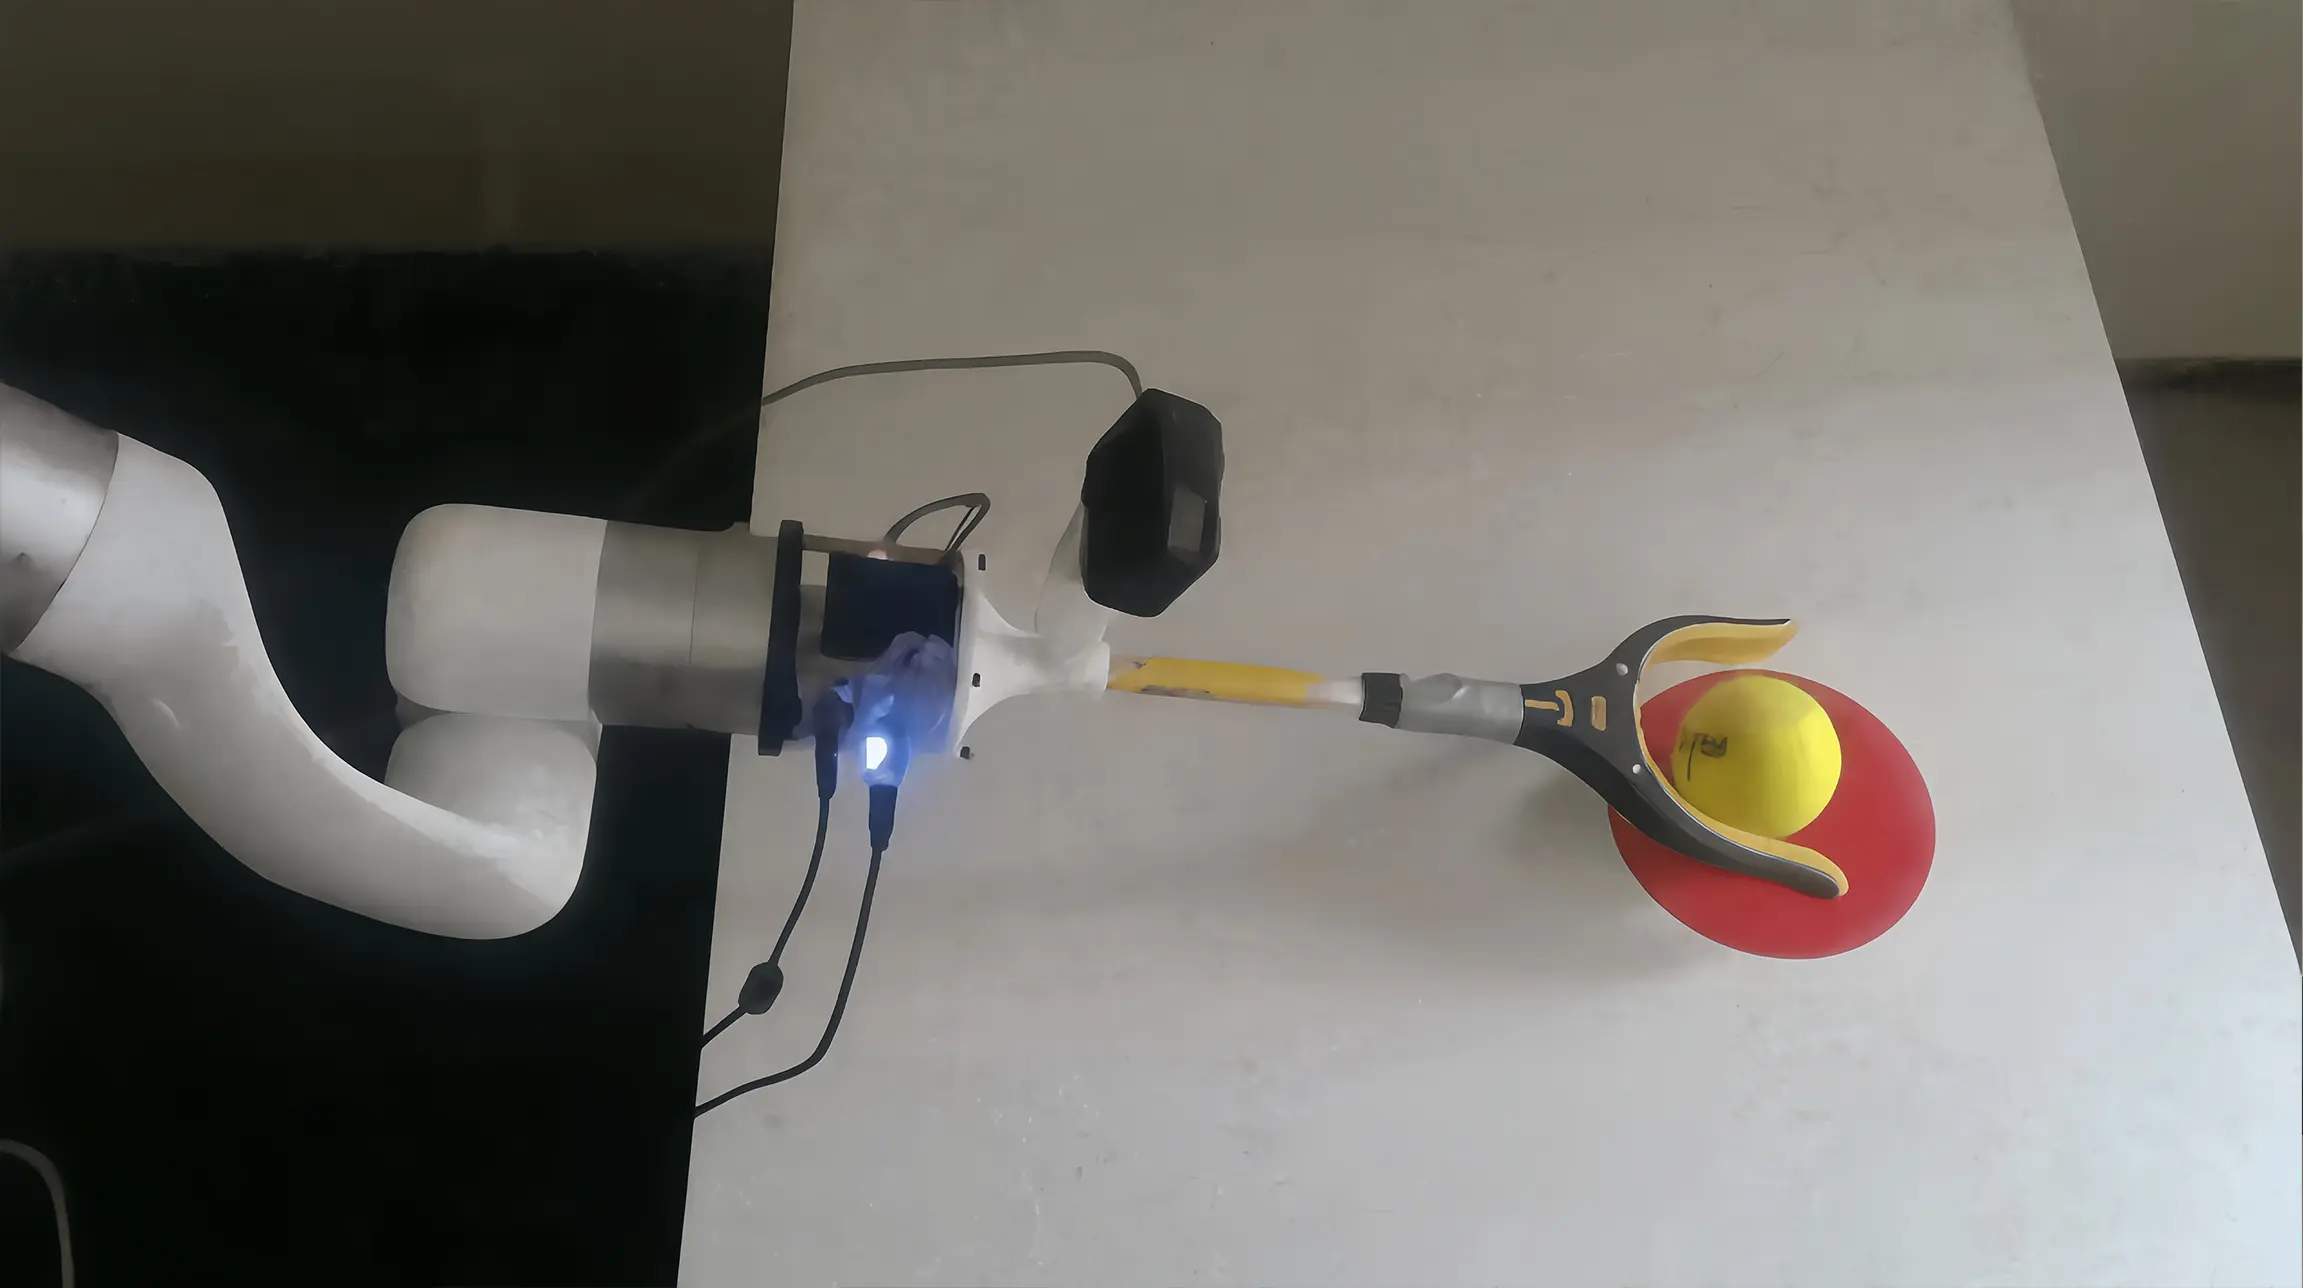
UFACTORY xArm 7 performed two challenging manipulation tasks using closed-loop visual behavior cloning: non-prehensile pushing and prehensile stacking. For each task, the policy was trained on roughly 1,000 diverse demonstrations and evaluated on novel objects.
Benefits achieved
Achieved approximately 87% success on pushing and 62% on stacking with unseen objects.
Policies remained robust under active human disturbances through closed-loop control.
The Challenge
Mainstream imitation-learning interfaces, such as kinesthetic teaching and teleoperation/VR, are slow, confined to the lab, and difficult to scale. As a result, the demonstration data they produce lacks the object and environment diversity needed for learned policies to generalize.
A portable demonstration device
A tool that anyone could use anywhere, enabling data collection beyond the lab.
A faithful, adaptable robot platform
A robot capable of accurately executing learned closed-loop policies while accommodating a non-standard, custom-actuated end-effector instead of a fixed factory gripper.
Why UFACTORY
7-DOF Redundancy
The xArm7's 7-DOF design provides the kinematic redundancy needed to reproduce human-style trajectories, giving learned policies the freedom to reach target poses through natural, flexible motion paths.
Developer-Friendly Control Stack
Its open control stack and Python SDK make it straightforward to stream learned actions in real time and to integrate a custom Dynamixel-driven end-effector, so researchers can adapt the platform to their own hardware without fighting the system.
Research-Lab-Accessible Price
Accessible Price
At a price point accessible to research labs, the xArm7 lowers the barrier to real-robot experimentation, letting teams move from simulation to physical validation without a prohibitive hardware budget.
A Recurring Research Platform
Together, these qualities are why the xArm series (xArm6 and xArm7) has become a recurring platform across leading robot-learning and embodied-AI research.
Not sure which model fits your workflow?
Our team will match the right robot and configuration to your needs.